Alex OliveriMicromouse
Micromouse
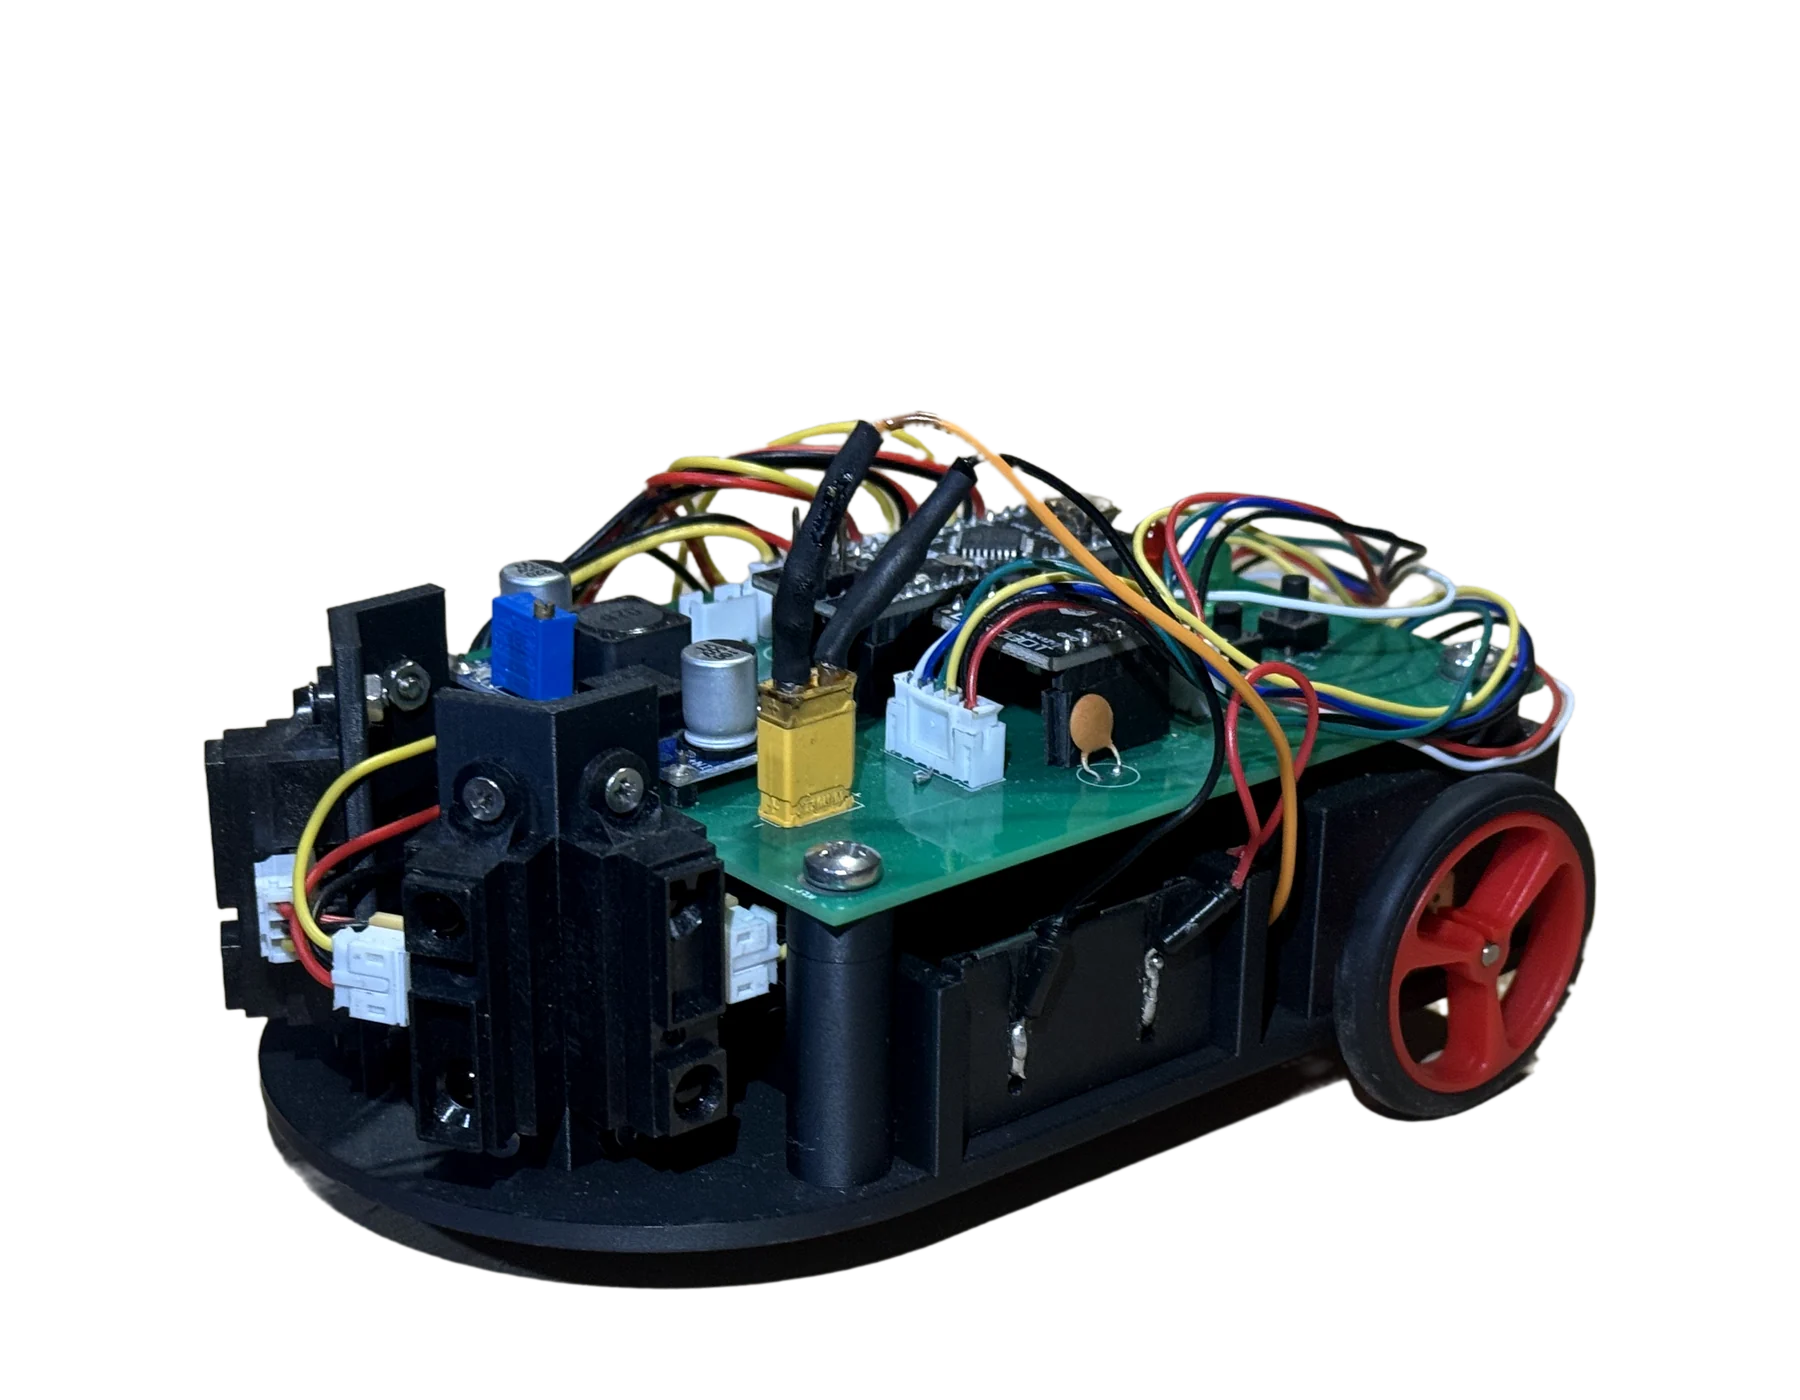
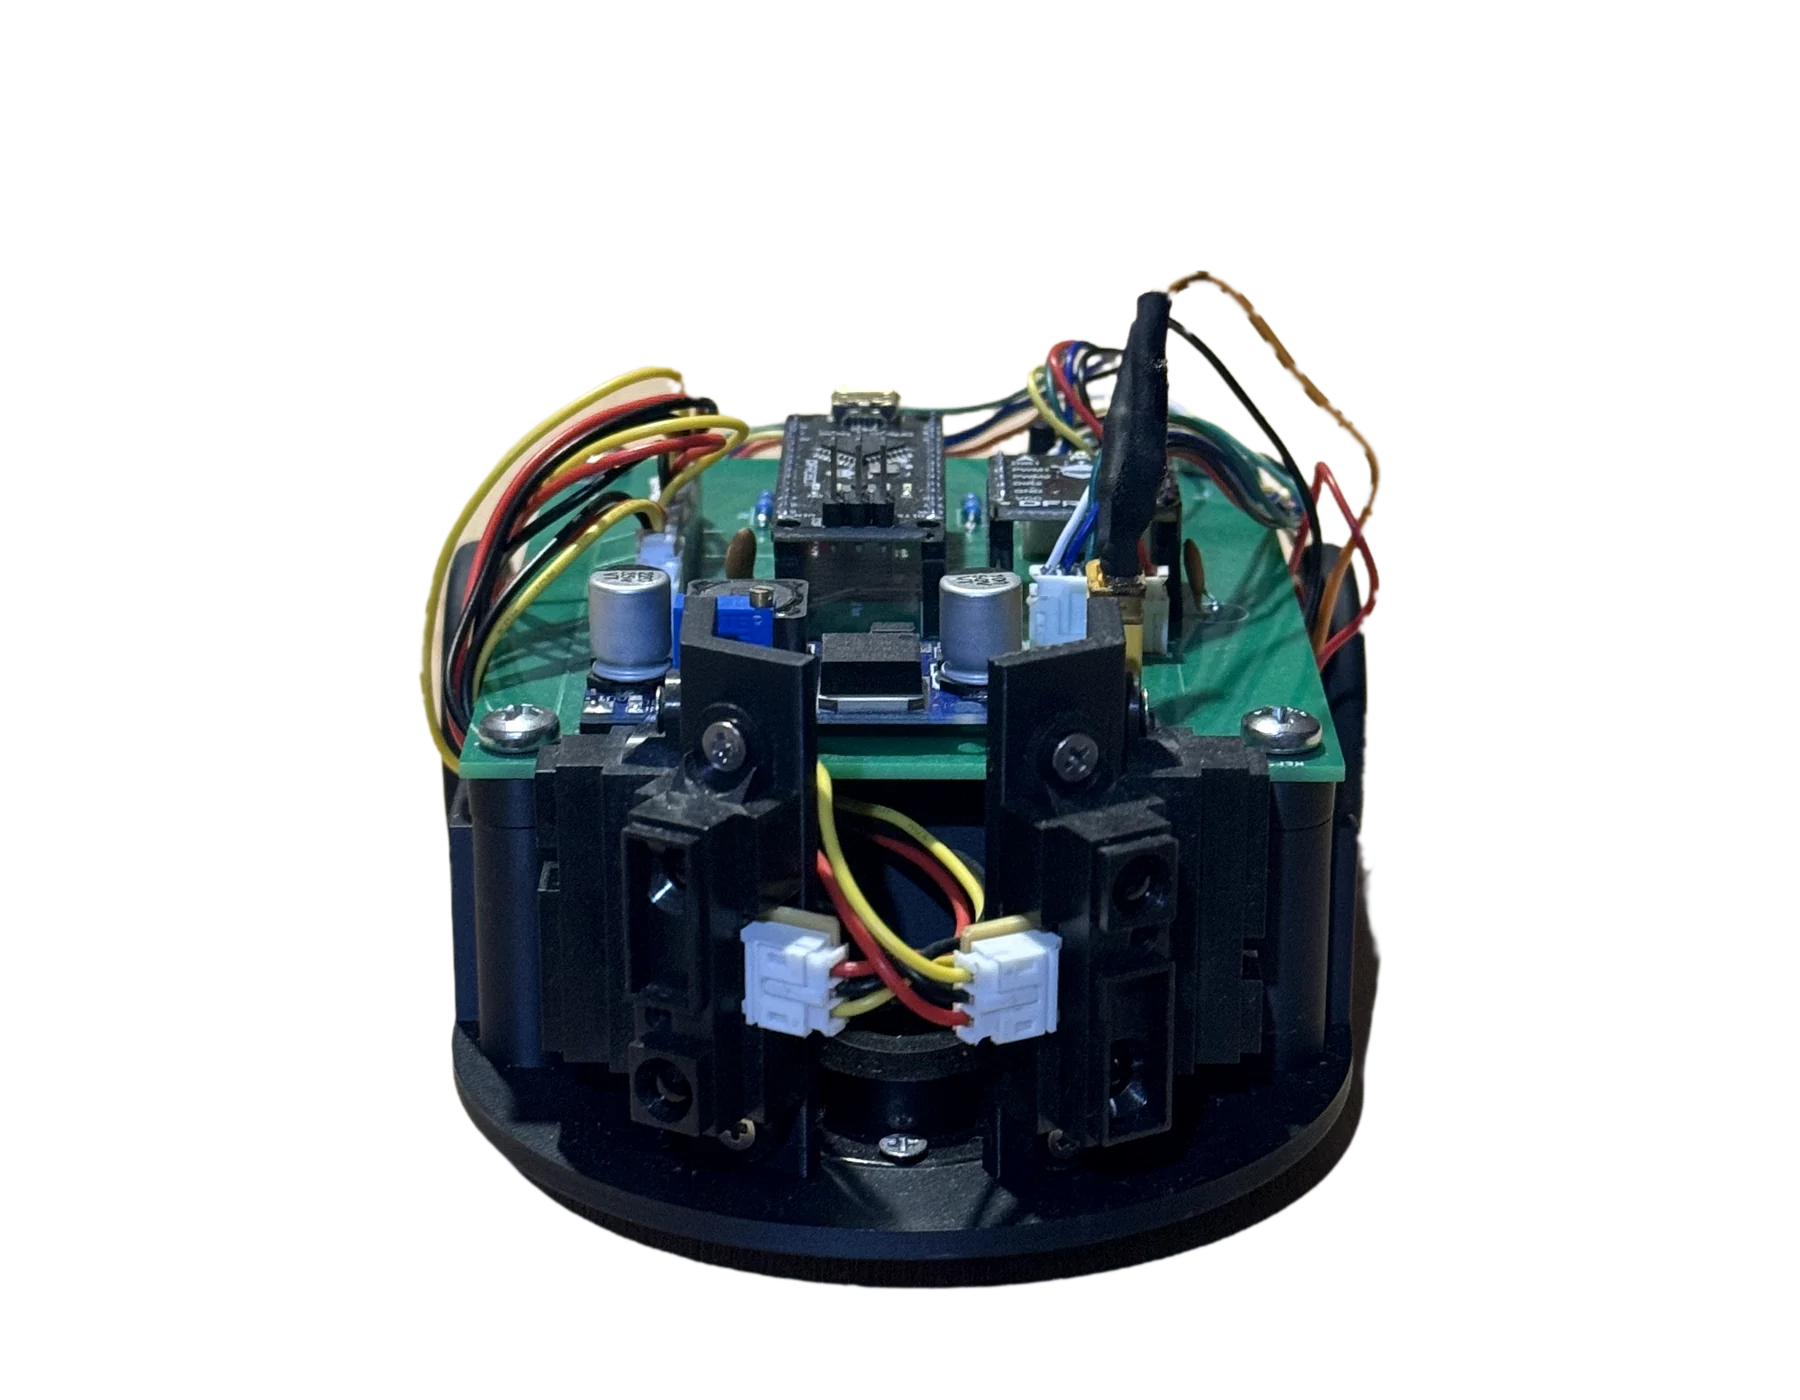
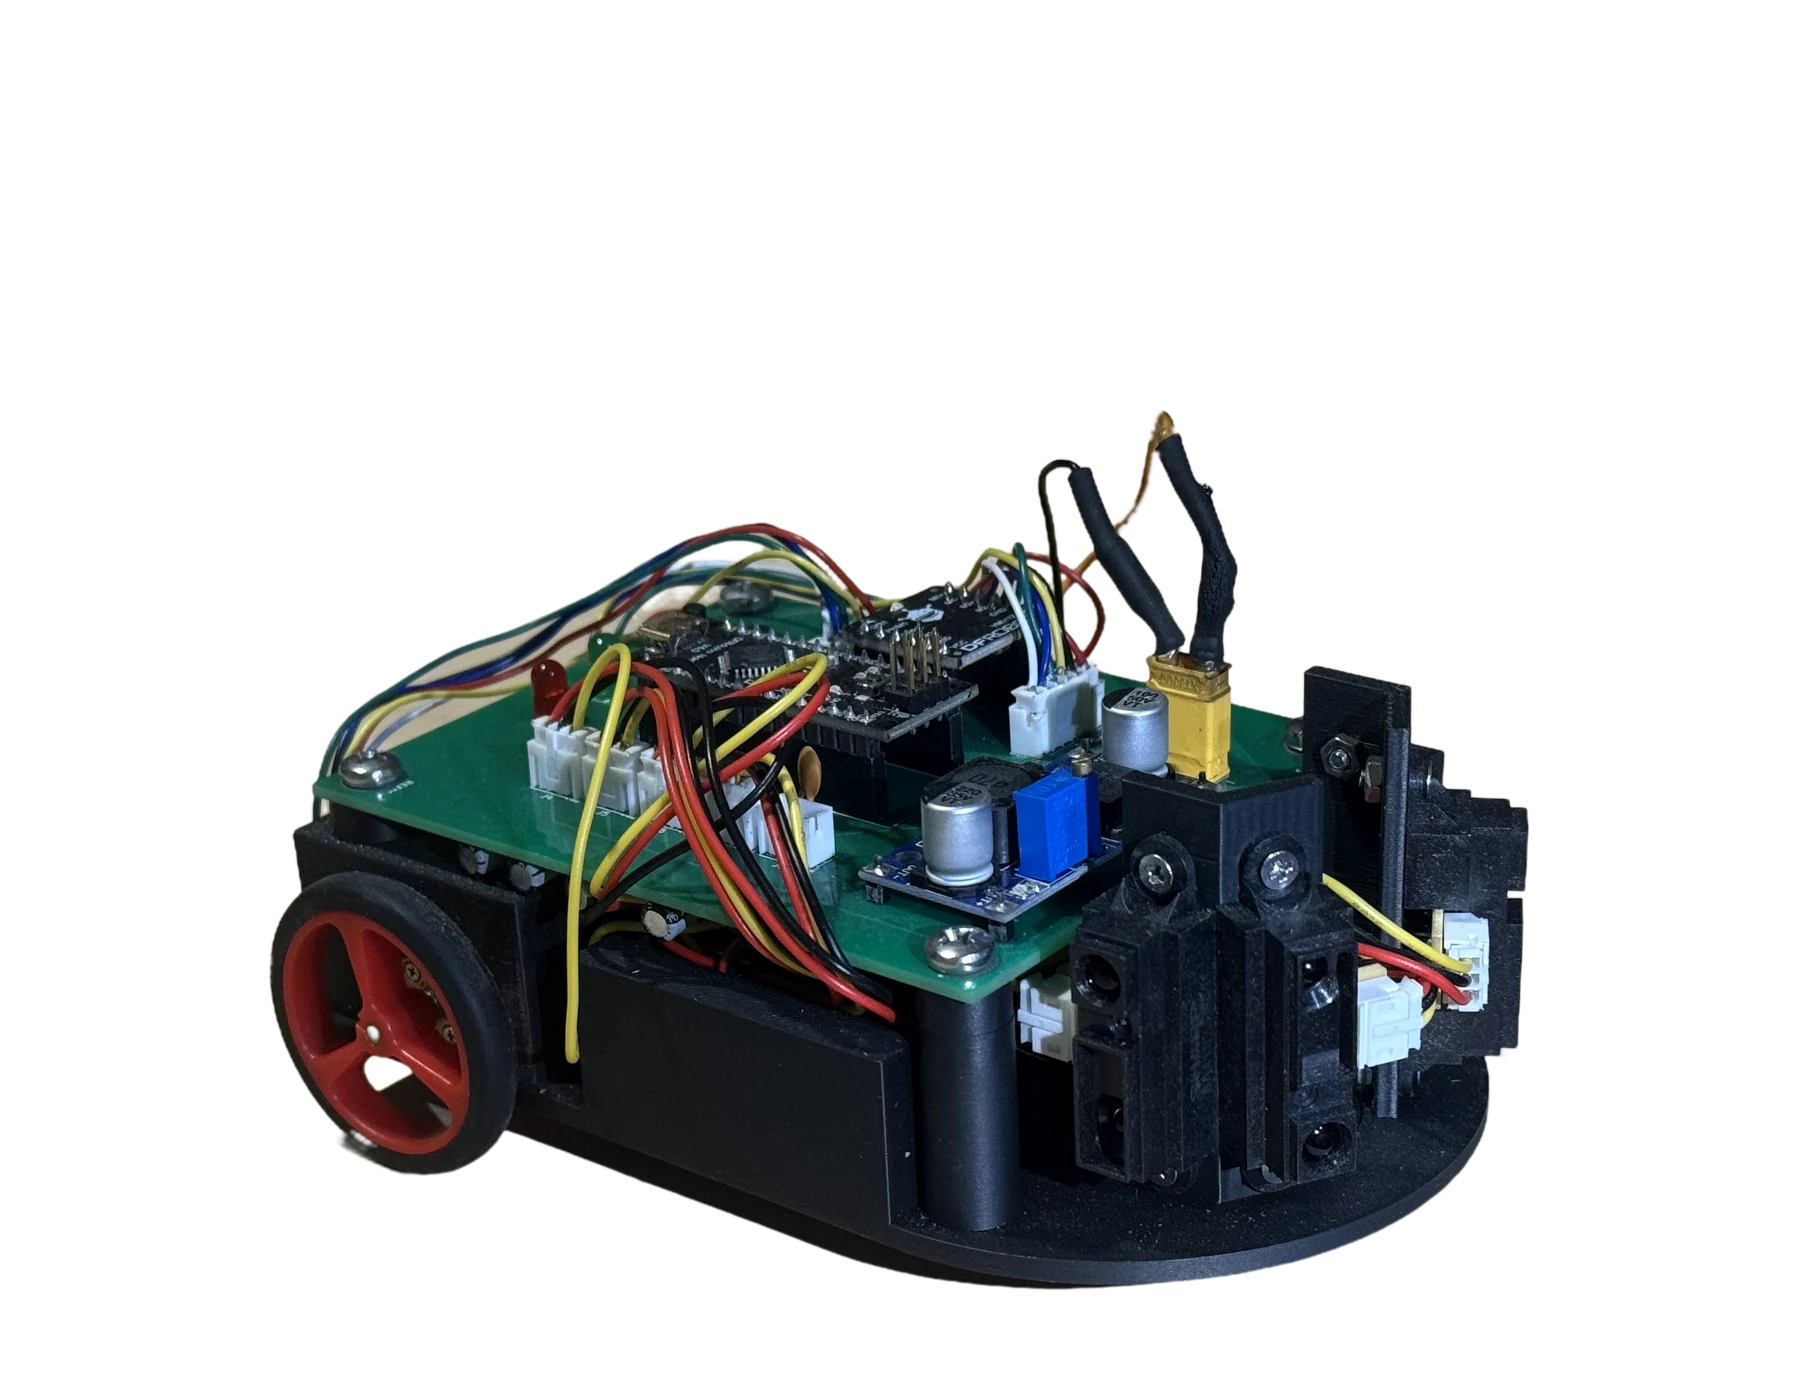
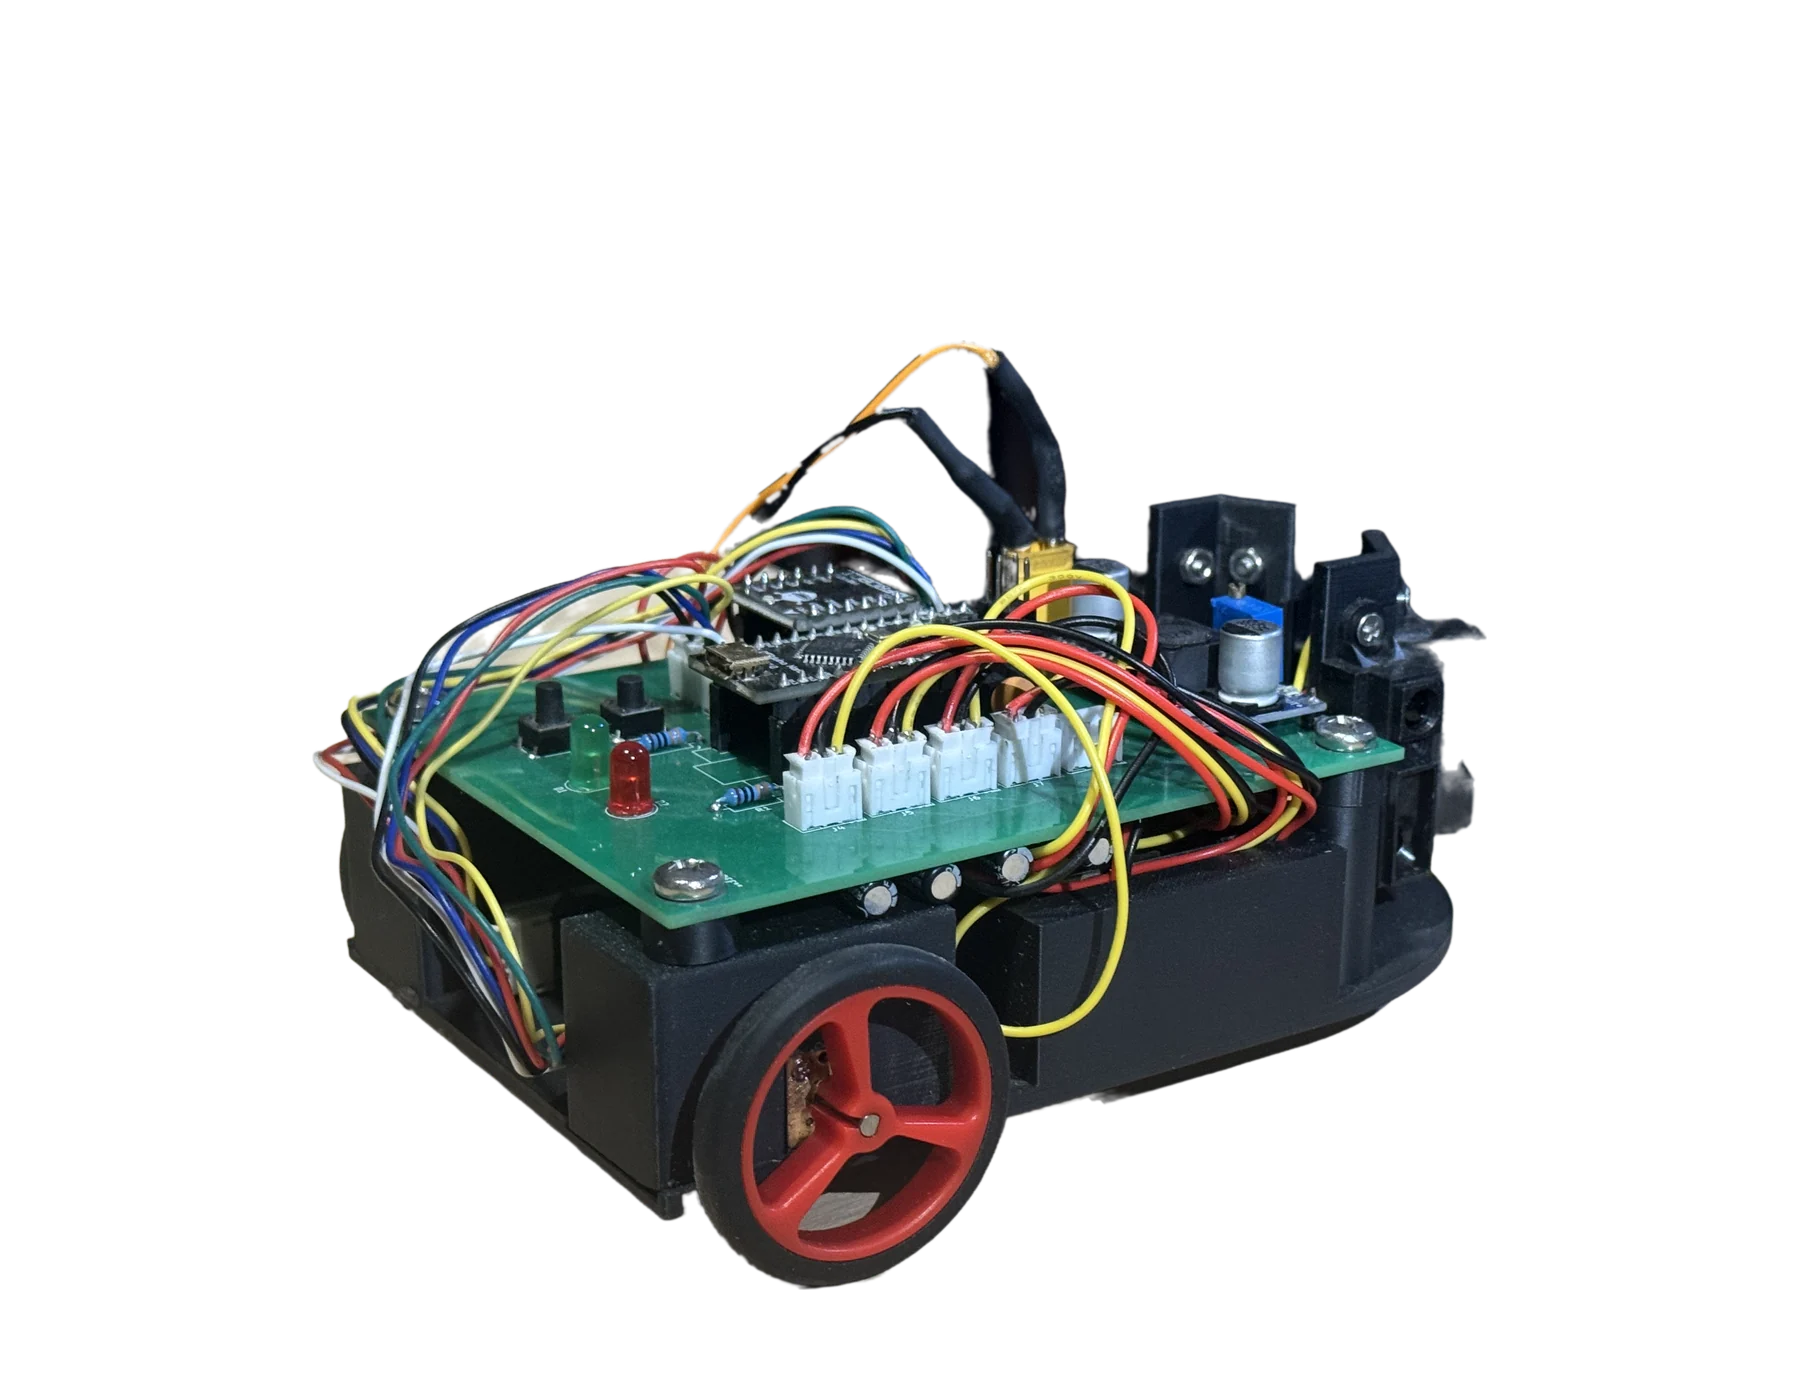
A maze-solving robot. It maps the walls as it drives and uses flood-fill to find the shortest way to the goal.
Scroll to drive
Cells to goal
3
315°
Front left
Alex OliveriMicromouse · design files
CAD · printed parts
The frame
Chassis, two motor brackets and four 5 mm spacers, straight from the CAD files. This is a live 3D model, so it turns smoothly as you scroll.
Design files to finished board
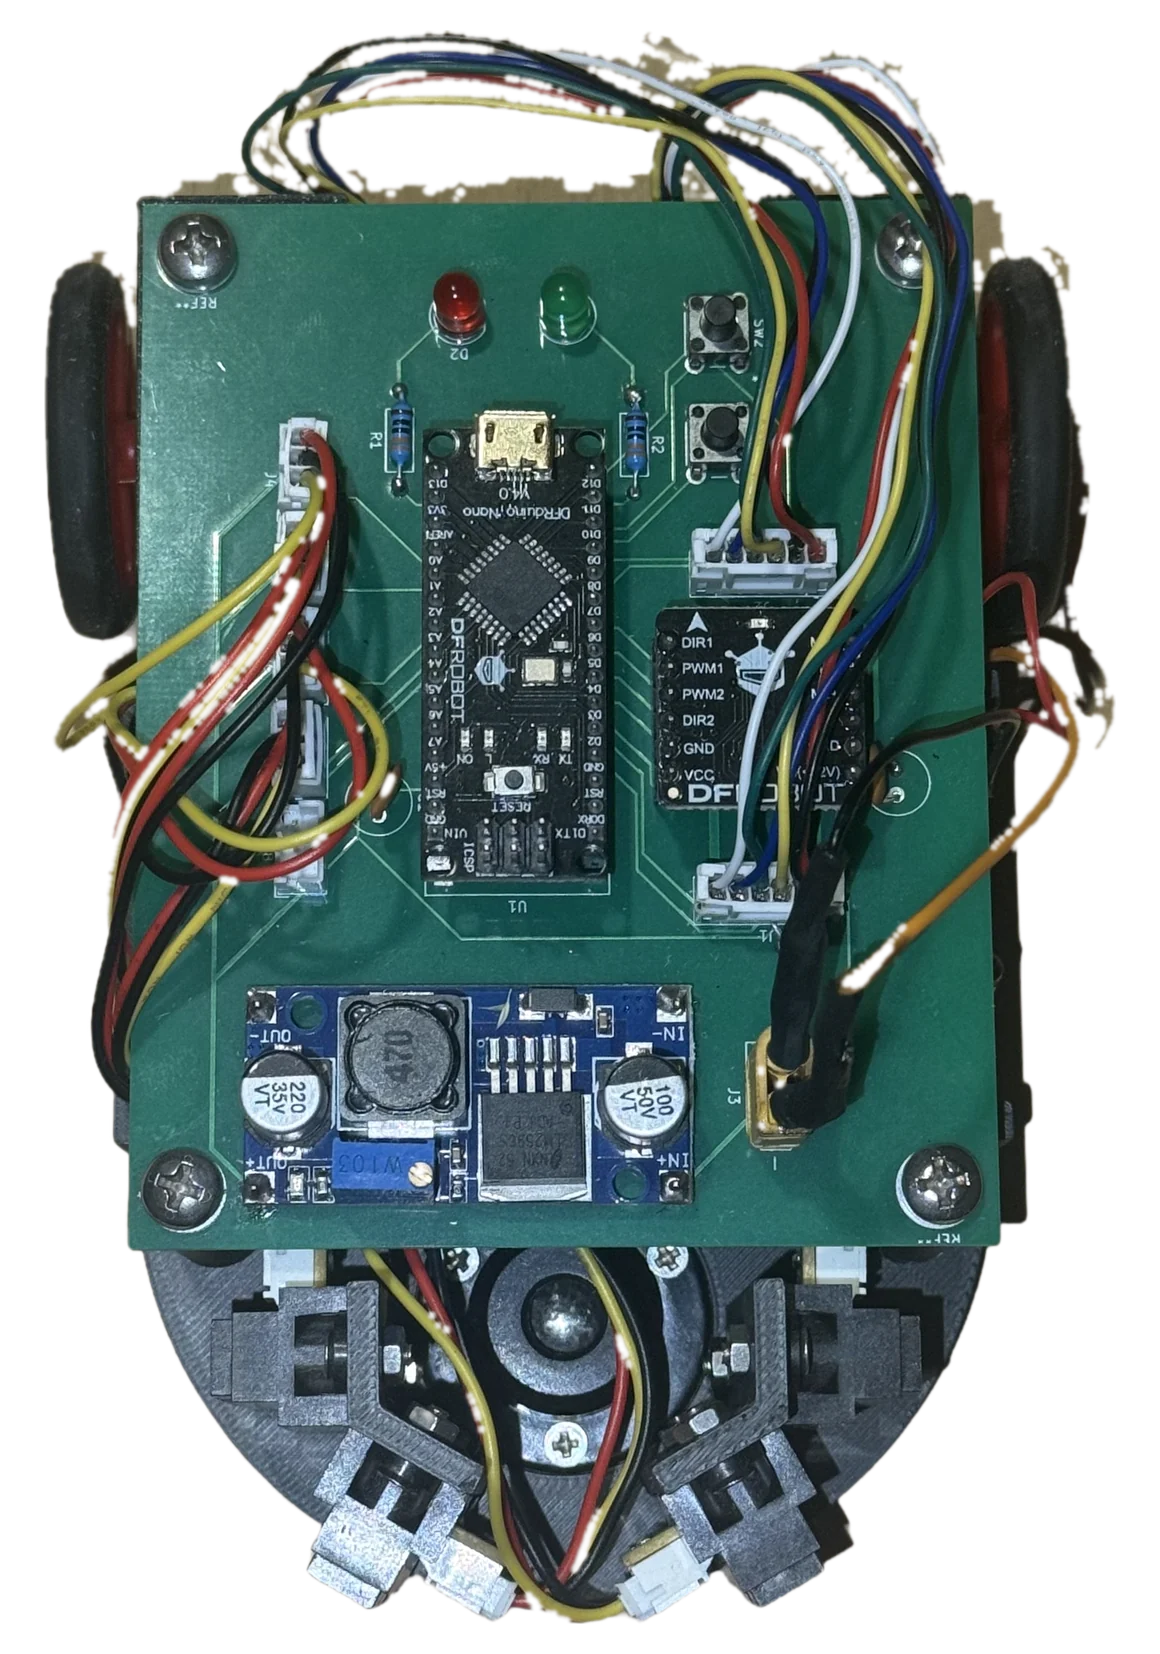
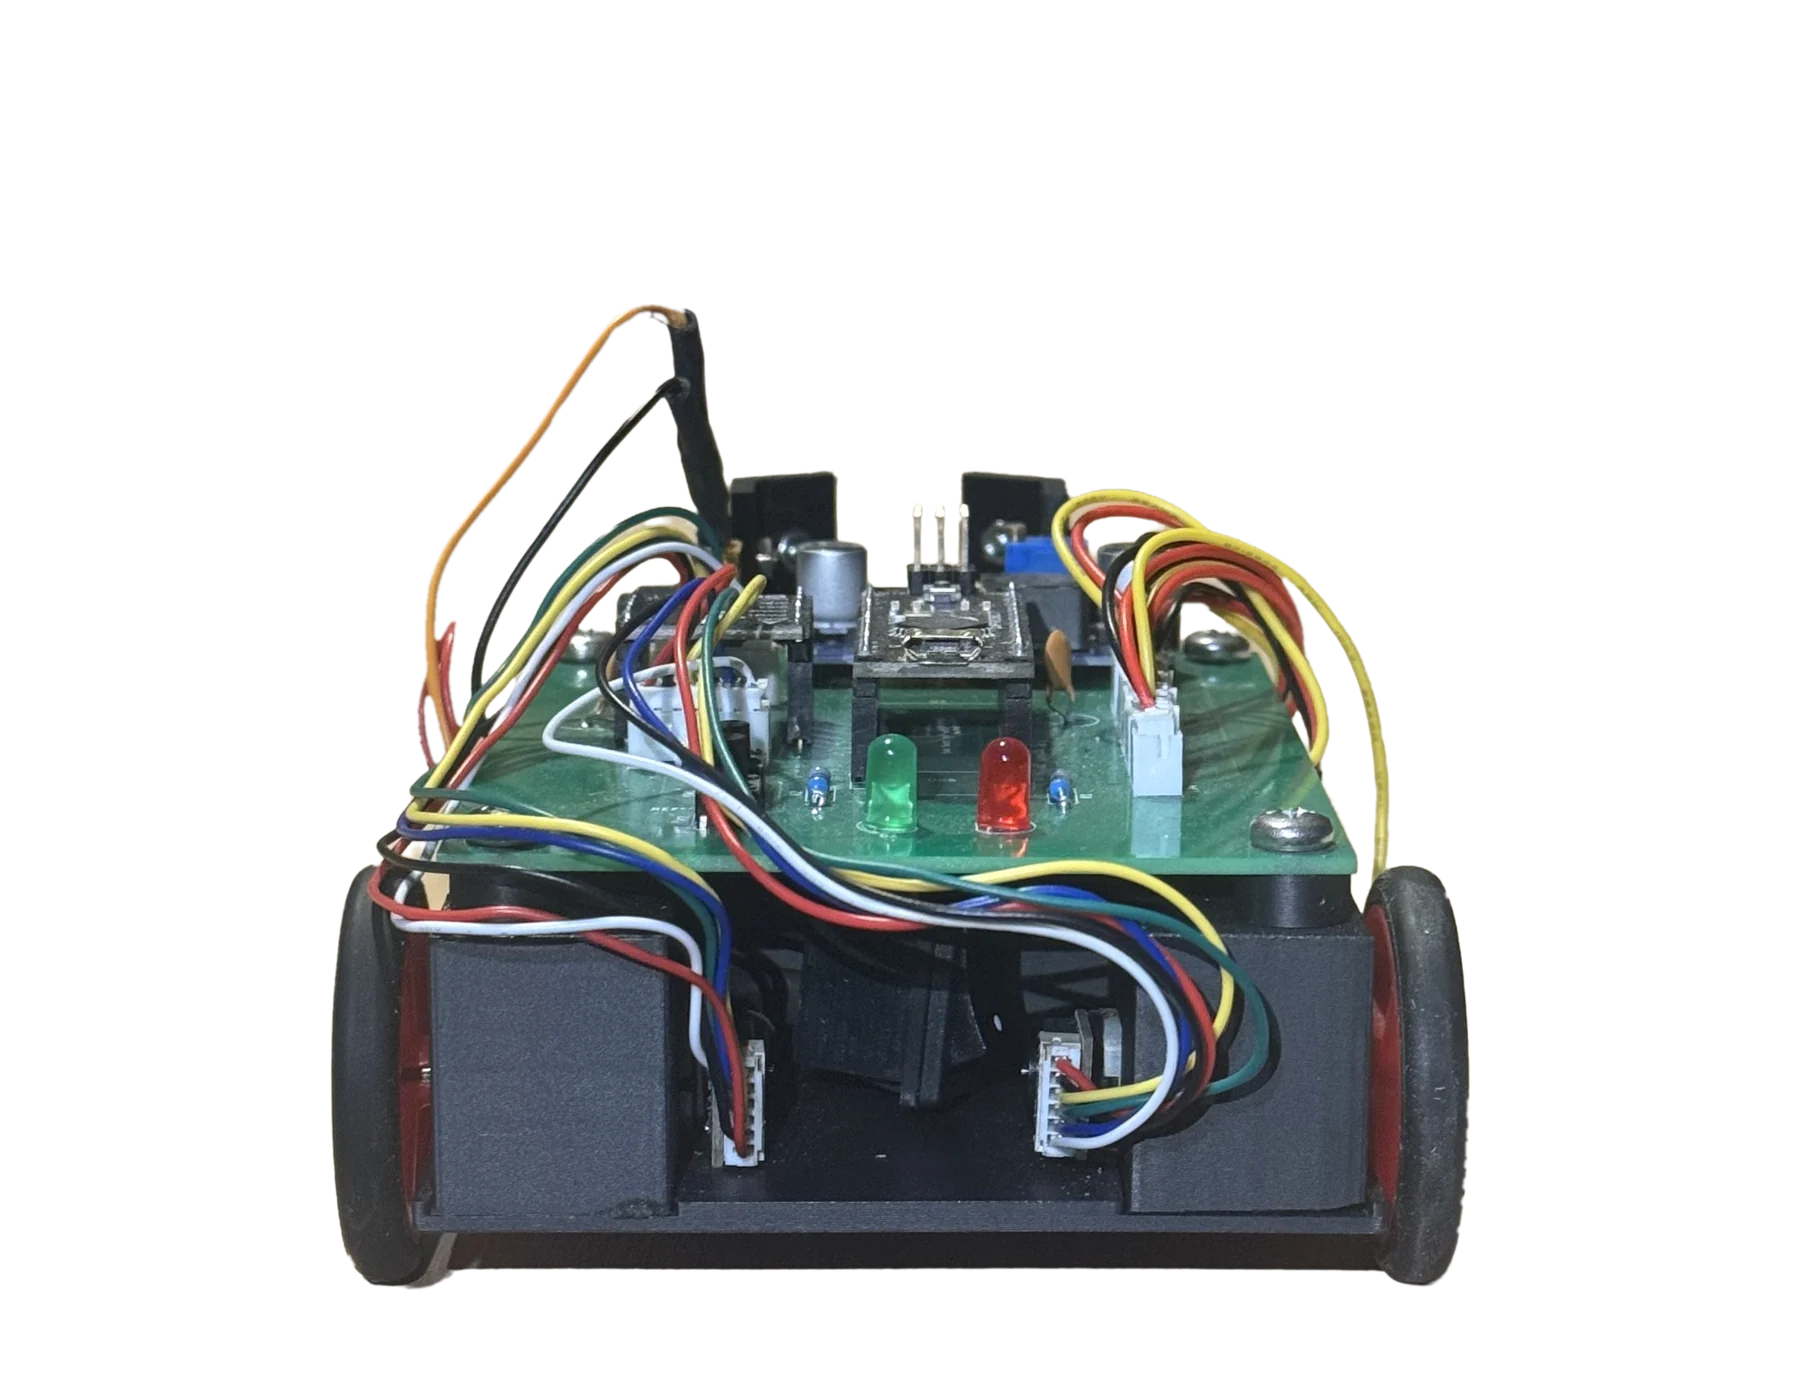
As designed, as built
- Board
- 84 × 105.5 mm, 2 layers, 1.6 mmEvery part is through-hole: 99 drilled pads.
- Tracks
- 0.3 · 0.5 · 1.0 mmSignal, power and motor. Ground is a pour across the back.
- Controller
- DFRduino Nano, U1Runs the flood-fill firmware, written in C++.
- Drive
- Dual motor driver, U2Direction and PWM per motor on D4 to D7.
- Power
- Battery on J3, buck converter U3Battery voltage to the motors, 5 V to everything else.
- Ports
- 2 motor, 5 sensor6-pin motor connectors, 3-pin sensor ports on A0 to A4 — four populated.
- Frame
- 90 × 143 mm chassisPlus two motor brackets and four 5 mm spacers.